


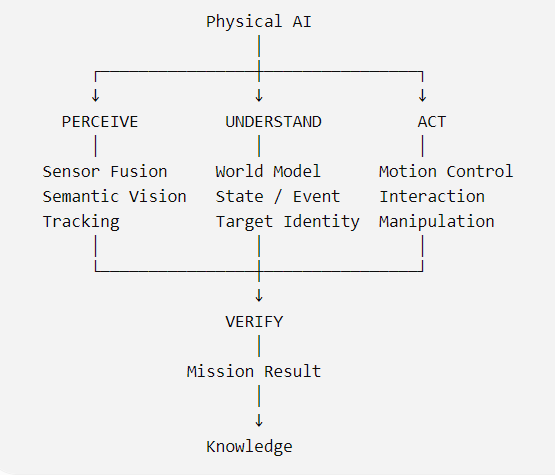
AiBrainBox = 通用 Physical AI Brain-Perceive → Understand → Act → Verify
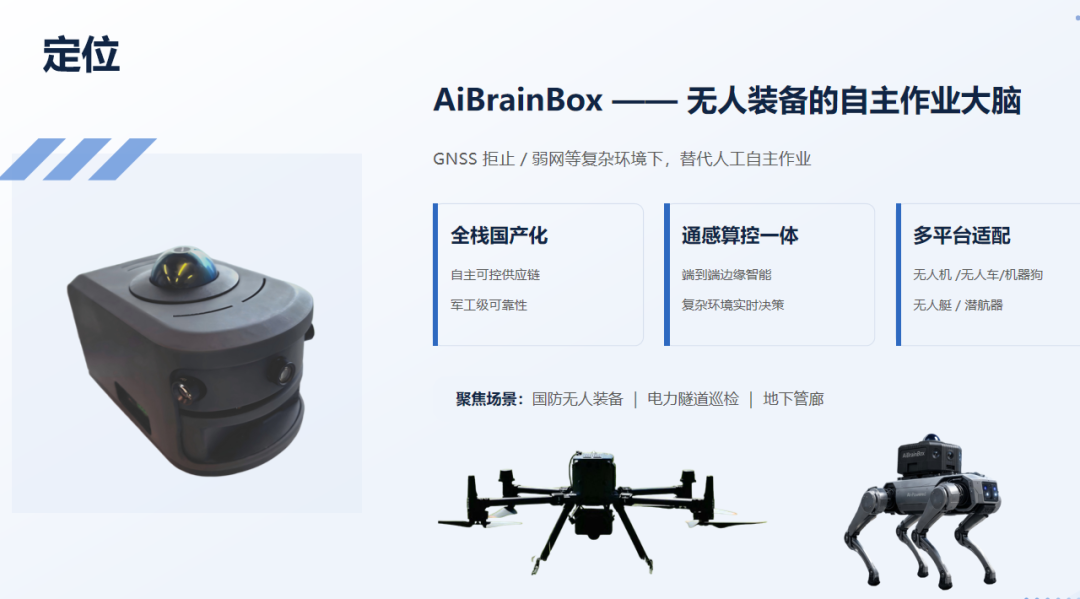
AiBrainBox:
让各种无人平台具备 Physical AI 能力。
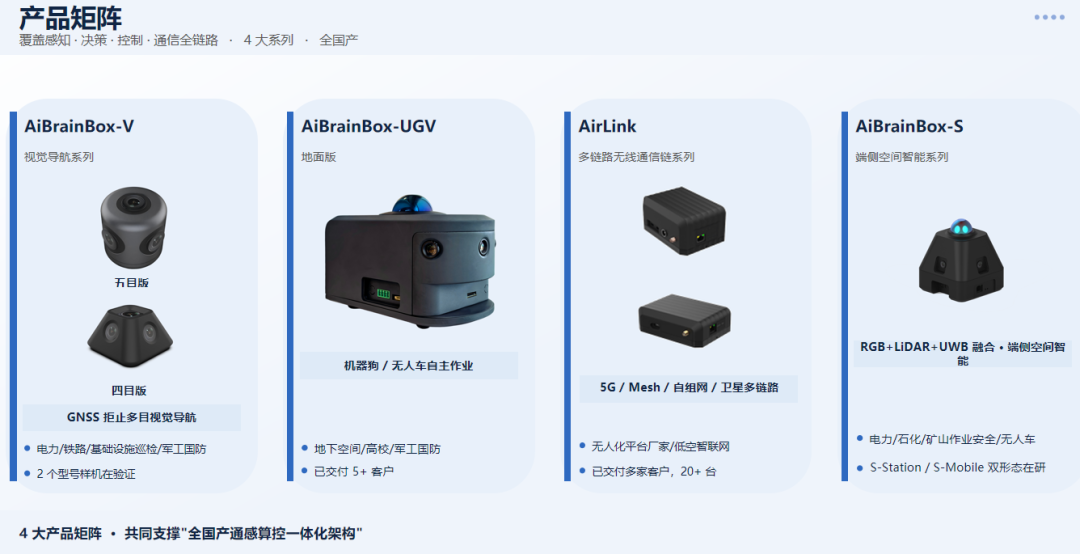
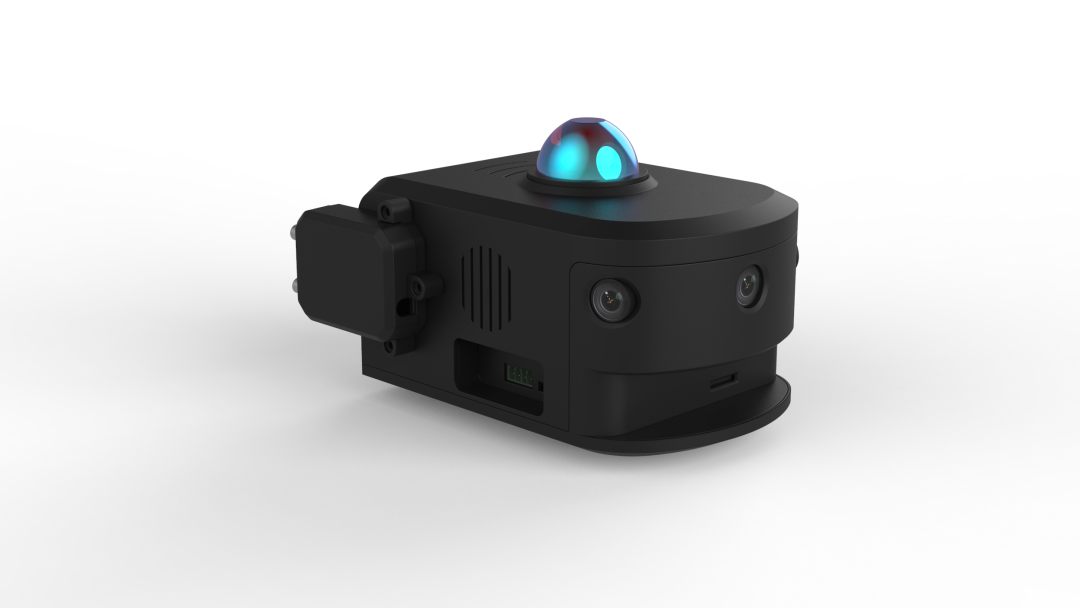
AiBrainBox = 通用 Physical AI Brain
Semantic Perception
Autonomous Approach
Tool / Payload Runtime
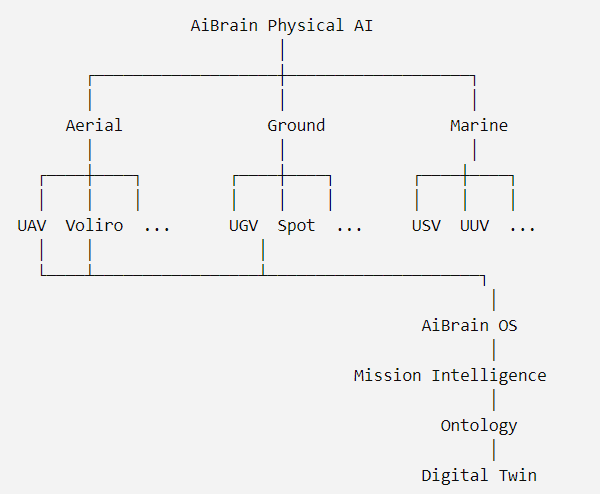
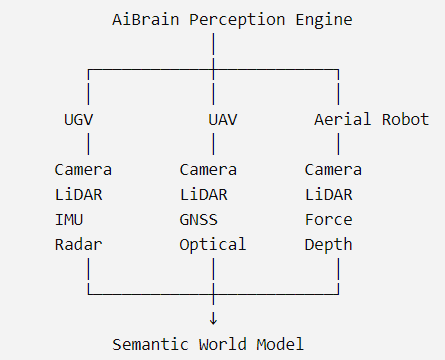
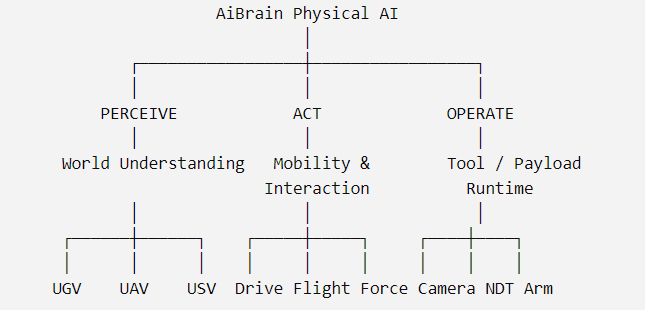
AiBrain Physical AI Architecture
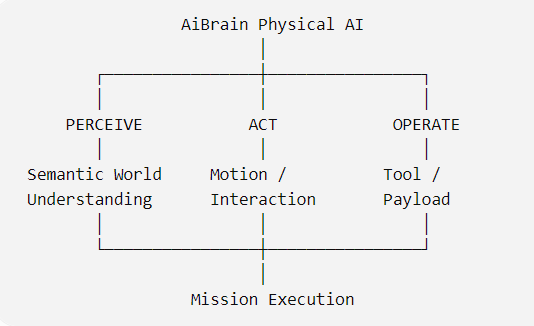
Layer 1 — Perceive
Semantic Perception & World Understanding
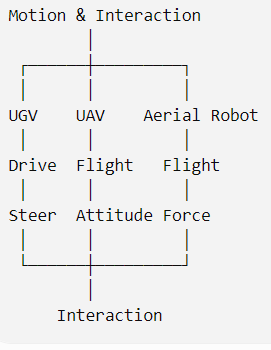
Layer 2 — Act
Motion & Interaction
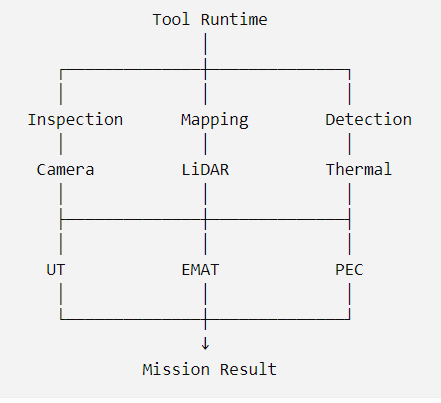
Layer 3 — Operate
Tool / Payload Runtime
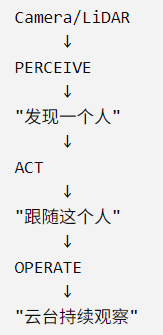
UGV和V可以共用一套Physical AI
比如 UGV:
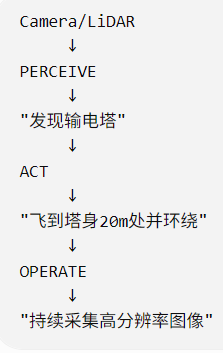
普通UAV:
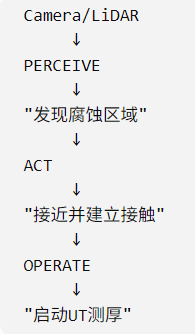
未来 Voliro 类:
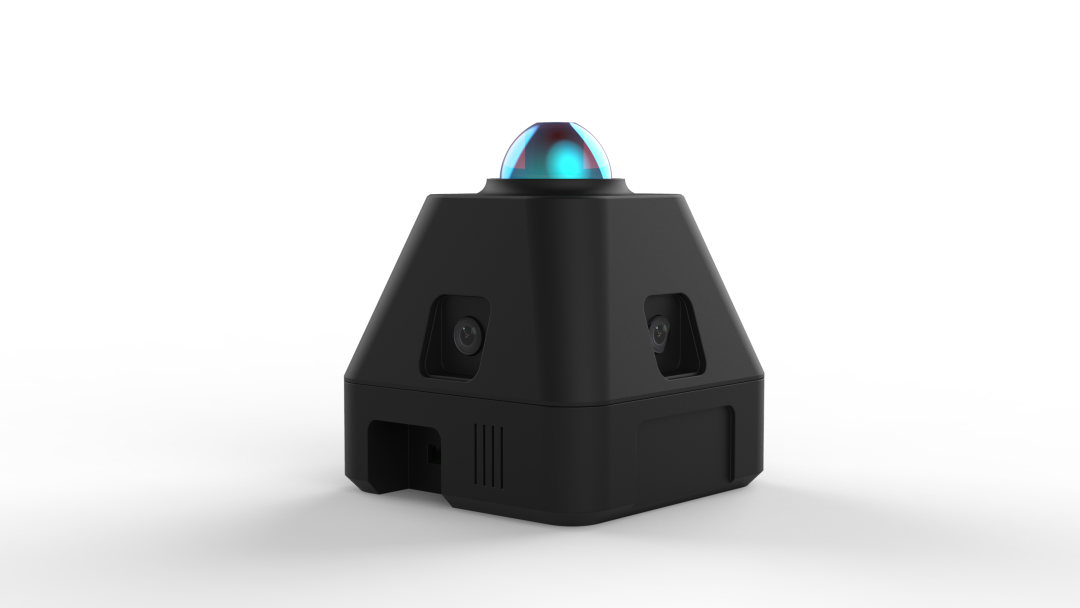
AiBrainBox-V就不再是“AI无人机载荷计算盒”,而是:
Aerial Physical AI Node
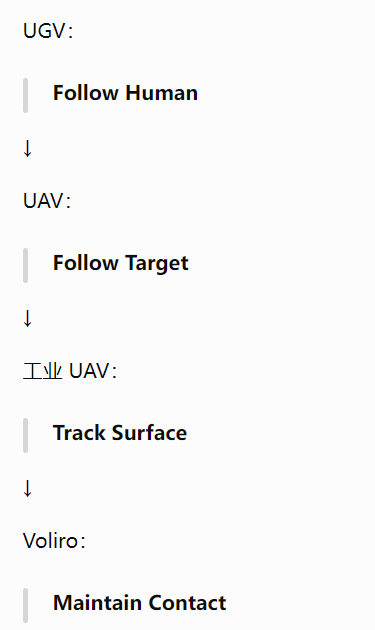
其实是同一个控制问题逐渐增加约束:
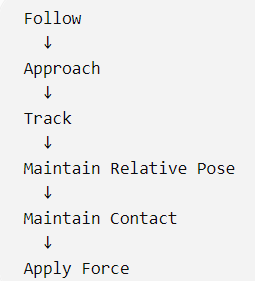
所以之前 UGV 做的:
Person Re-ID + Detection + Tracking + Semantic State
并不是只能用于 UGV。
它可以直接演化成:
Target Identity + Tracking + Relative Pose + Interaction State
这就是跨平台 Physical AI。
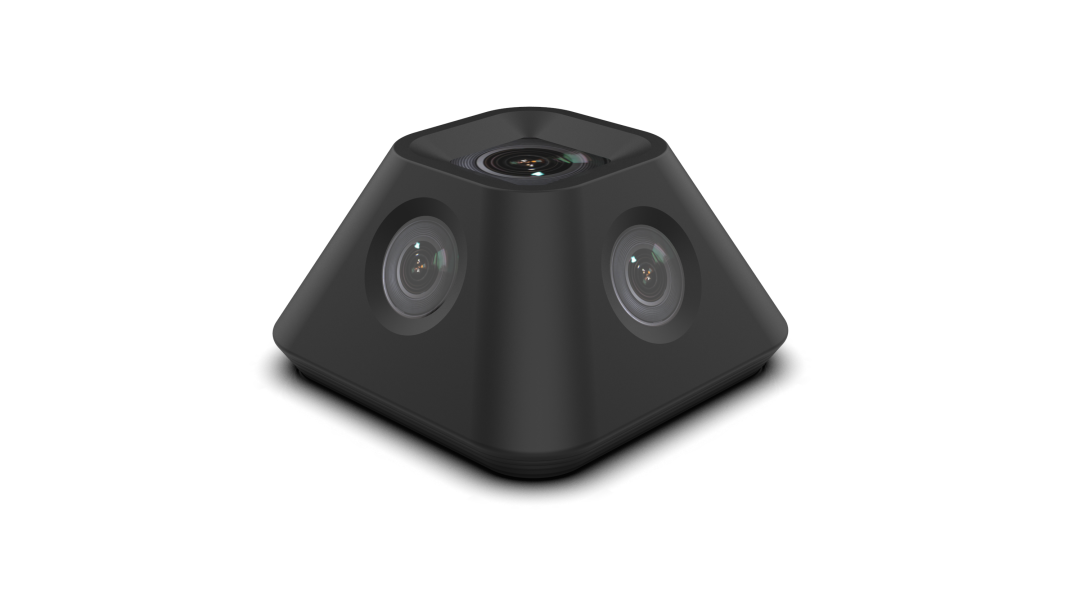
AiBrainBox-V = Aerial Physical AI Node
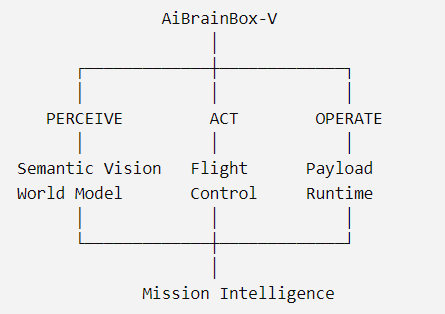
Physical AI = Perceive → Understand → Act → Verify
例如:
UGV
发现目标 → 接近 → 跟随 → 确认目标状态。
UAV
发现铁塔 → 接近 → 拍摄 → 确认图像质量。
Voliro
发现腐蚀 → 接触 → UT测量 → 确认测量有效。
修复机器人
发现腐蚀 → 修复 → 再次检测确认修复成功。
这才是真正的 Physical AI Loop。
Physical AI:
World
↓
Perceive
↓
Understand
↓
Plan
↓
Act
↓
Observe Result
↓
Verify
↓
World
是:
AI Control Loop
所以 AiBrainBox 的真正价值应该逐渐从:
AI Compute
转向:
Physical AI Runtime


 扫一扫


 290

 被折叠的 条评论
为什么被折叠?
 到【灌水乐园】发言


